Objective
Balance an inverted pendulum arm using a reaction wheel, connecting the physical system to a mathematical model and a control strategy.
Control Systems
Modelled system dynamics in MATLAB/Simulink and implemented state-feedback control, achieving stable balancing for four seconds from a 10° initial offset.
Balance an inverted pendulum arm using a reaction wheel, connecting the physical system to a mathematical model and a control strategy.
Worked in a five-person team to derive the state-space model, simulate it in MATLAB and compare the simulation with physical hardware. The system used an IMU and a repurposed 24 V drill motor, without a custom PCB.
Implemented a state-feedback controller using the system dynamics model developed in MATLAB/Simulink.
Achieved stable balancing for four seconds from a 10° initial offset.
The project includes interactive mathematical reference materials and a structured video presentation. These materials have not yet been added to this repository.
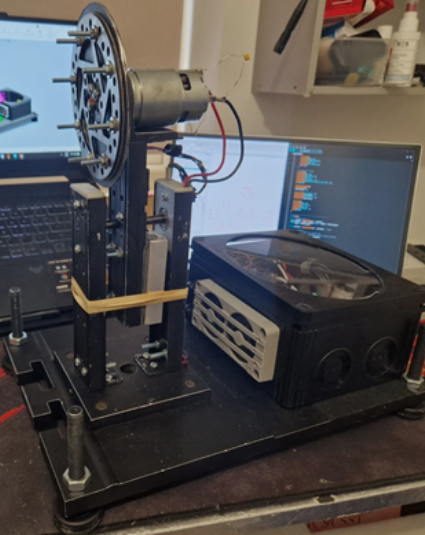
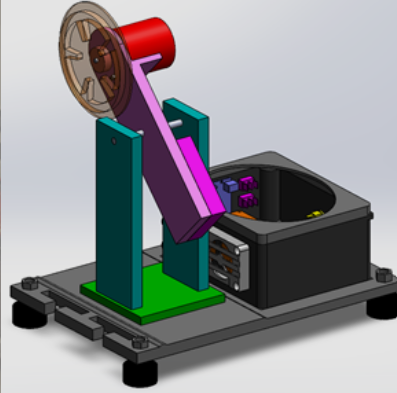
Project footage is not available yet. Demonstrations and process walkthroughs will be added here.