Concept & research
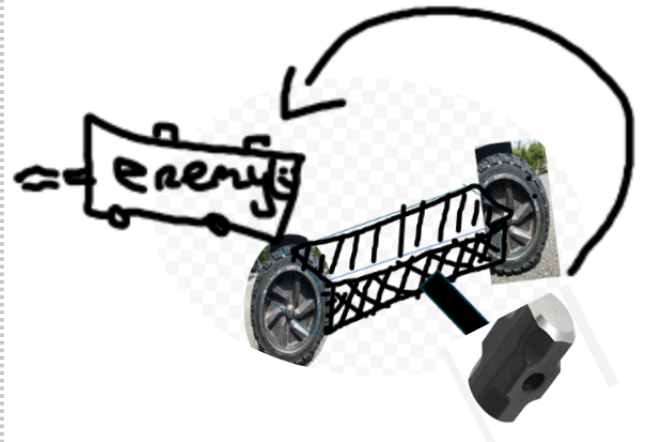
The team investigated torque-reaction weapon systems and reviewed existing combat robot designs. Rapid motor reversal was selected to rotate the robot around fixed wheels and deliver a strike through angular momentum.
Combat Robotics
Led full system architecture of a featherweight combat robot. Secured €2,000 in independent sponsorship. Applied MATLAB modelling to optimise rotational dynamics, achieving a 35% increase in rotational force and 95% competition reliability.
The team investigated torque-reaction weapon systems and reviewed existing combat robot designs. Rapid motor reversal was selected to rotate the robot around fixed wheels and deliver a strike through angular momentum.
MATLAB models explored angular momentum transfer, rotational dynamics and achievable force. The modelling informed motor selection and provided a way to evaluate the weapon concept before fabrication.
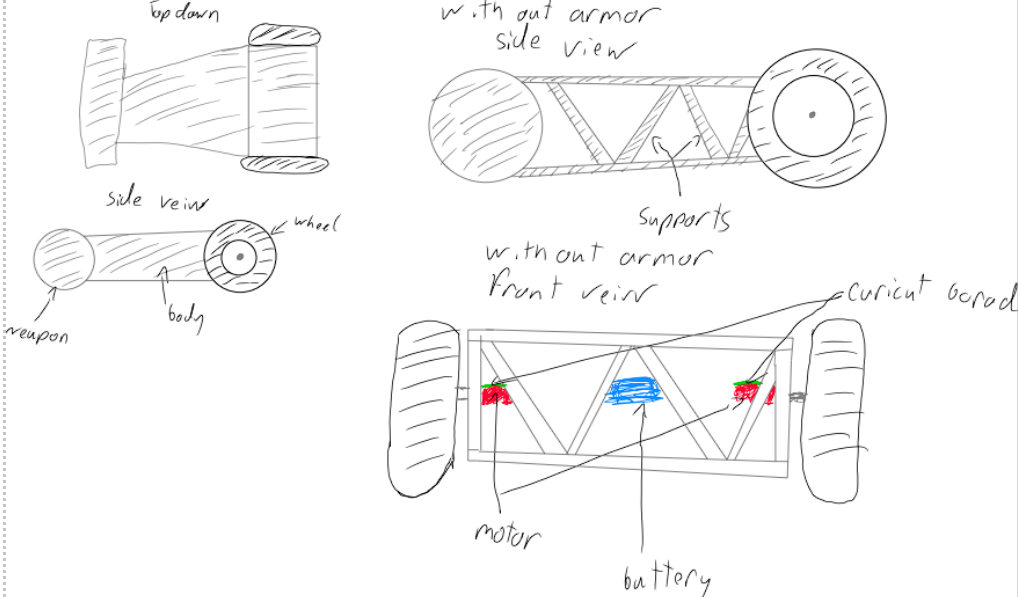
The existing project documentation describes a 6S LiPo power system, electronic speed controllers and a steel frame within the 12 kg featherweight limit. Integration balanced impact resistance, weight distribution and drivetrain responsiveness.
The five-person team divided fabrication and integration work across the four-month build. Iterative testing identified mechanical stress points and motor heating, leading to changes in thermal management and operating duty cycles.
The homepage reports €2,000 in sponsorship, a 35% increase in rotational force and 95% competition reliability. The project brought together mathematical modelling, system integration and team coordination.
Project footage is not available yet. Demonstrations and process walkthroughs will be added here.