Control development
Worked in a six-person team on an aluminium-frame mechanism with one degree of freedom, an Arduino, a DC motor and an ultrasonic sensor.
Autonomous Systems
Developed an Arduino-based pick-and-place mechanism with ultrasonic sensing, a DC motor and PID control for a smooth approach to the object.
Worked in a six-person team on an aluminium-frame mechanism with one degree of freedom, an Arduino, a DC motor and an ultrasonic sensor.
Configured the ultrasonic sensor and debugged the mathematical model used to approach an object. PID control smoothed the approach; the build did not use encoders or autonomous task sequencing.
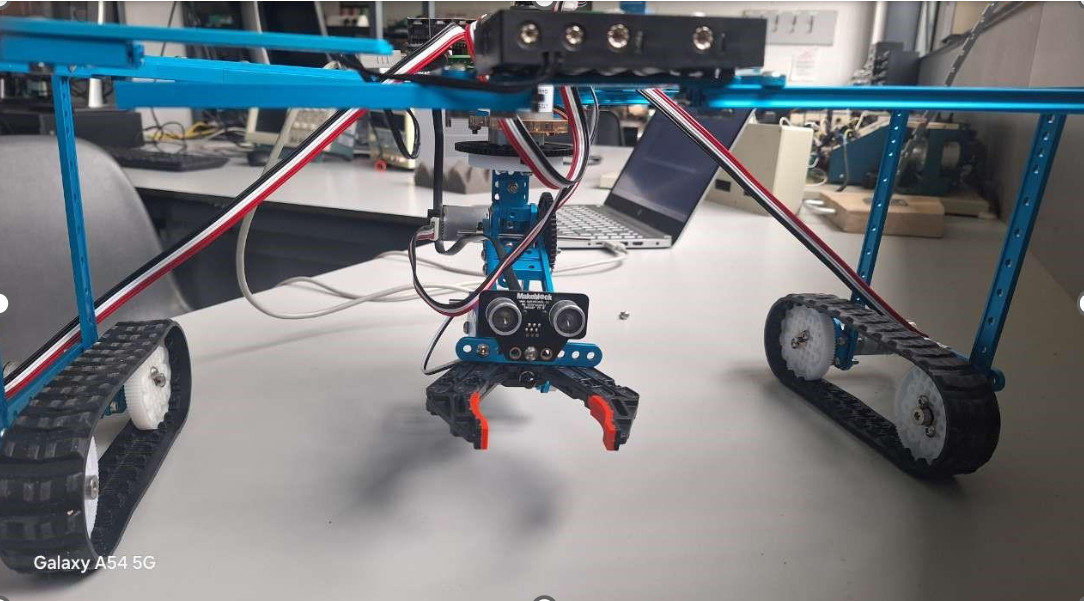
Designed a gripper that automatically closed around objects once the robot reached the target distance.
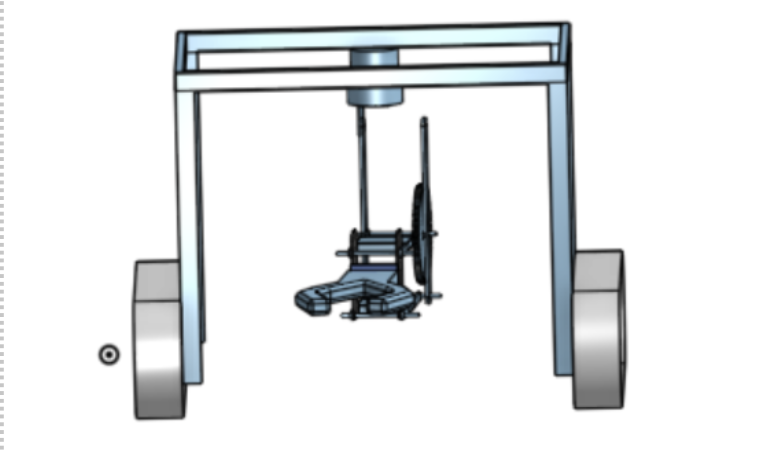
The CAD model and assembled robot photographs below document the mechanical system. A detailed test log and demonstration video are still to be added.
Project footage is not available yet. Demonstrations and process walkthroughs will be added here.